


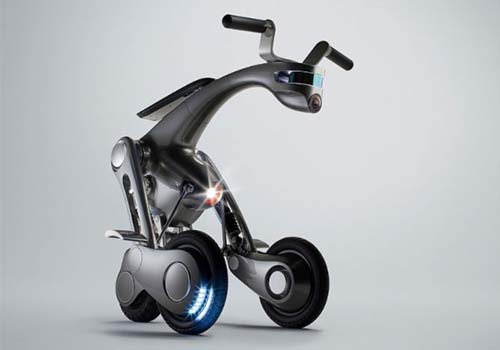
Before machines officially entered human life, horses have always been our faithful and reliable companions. Not only are they our means of transportation, but they also live with us and help us in various ways, such as carrying goods or going hunting together. Although today's human beings are already in the advanced "machine age", they seem to have never forgotten the companionship brought by this important animal companion from spirit to life, so some persistent engineers are going to try to use the current civilization technology to create a new world.
رفيق آلي مثل هذا الحصان.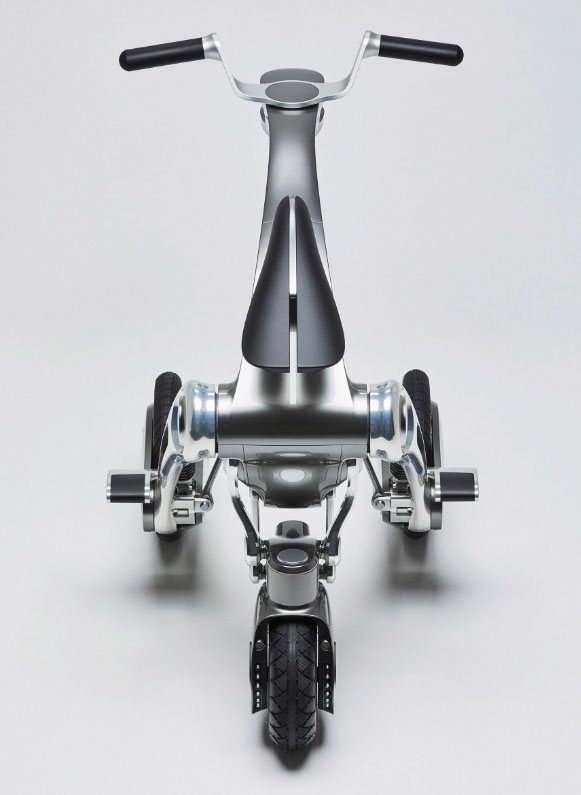 The most successful and impressive of these is probably the rideable robot CanguRo, which was developed by Shunji Yamanaka of the Future Robotics Research Center (FuRo) of the Chiba Institute of Technology in Japan. Its functional performance is considered perfect. It meets the requirements that humans once had for horses.
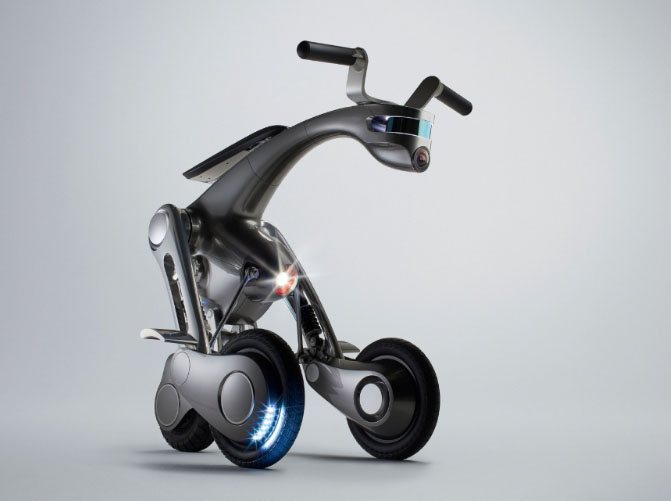 When you see CanguRo for the first time, you may think it is a sci-fi character in a Hollywood robot movie, and in terms of shape, it is not designed as a quadruped robot similar to a horse, but uses a The cooler and more unique inverted three-wheel design makes the robot look more like a big kangaroo when it is in its folded form.
وربما لهذا السبب أطلقوا أيضًا على الروبوت اسم "كانغورو" باللغة الإيطالية.
Although CanguRo has nothing to do with horses in terms of shape, it can indeed perform the same tasks as horses, including being able to be ridden or transported goods. It can also follow the owner obediently like a pet, even through voice and specific Actions communicate and interact with the host.
CanguRo قادر على إكمال السلوكيات الشبيهة بالحصان المذكورة أعلاه عن طريق التبديل بين الوضعين Roid وRide. يمكن اعتبار وضع Roid بمثابة وضع الروبوت الخاص به.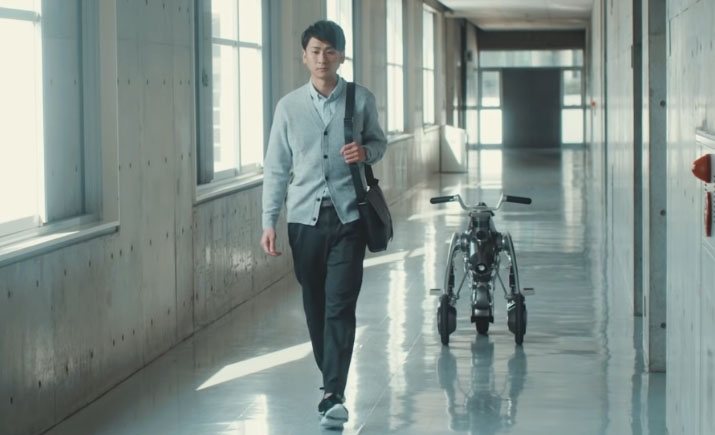 في هذا الوقت، ستعمل السيارة على تقليل المسافة بين العجلات الأمامية والخلفية، بحيث يبلغ طول الجسم 555 ملم فقط، كما سيتم تخزين وسائد المقعد معًا. في هذا الوضع، سيتبع CanguRo المالك بطاعة في أي مكان حتى تتصل به بالمنزل أو تستقل السيارة.
So how does CanguRo follow its owner obediently, bypass all kinds of obstacles and pedestrians on the road smartly, or not go on the wrong street when returning home? In fact, similar to self-driving cars, it is also realized by the joint action of sensor hardware and software related to intelligent driving. 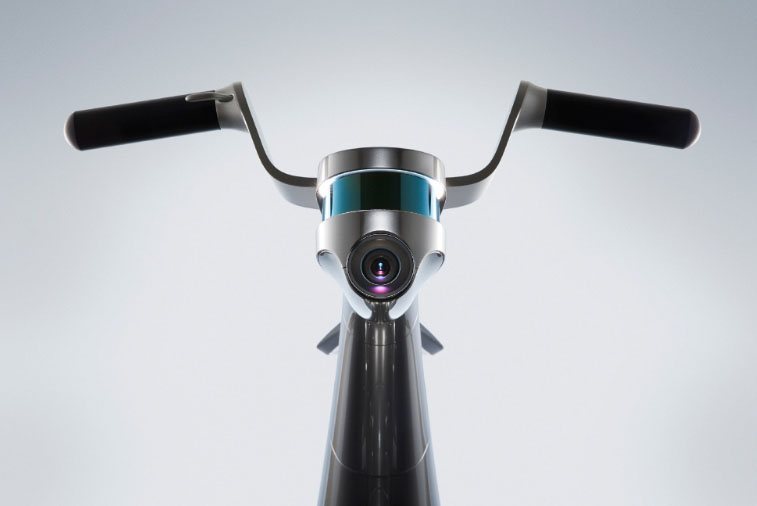
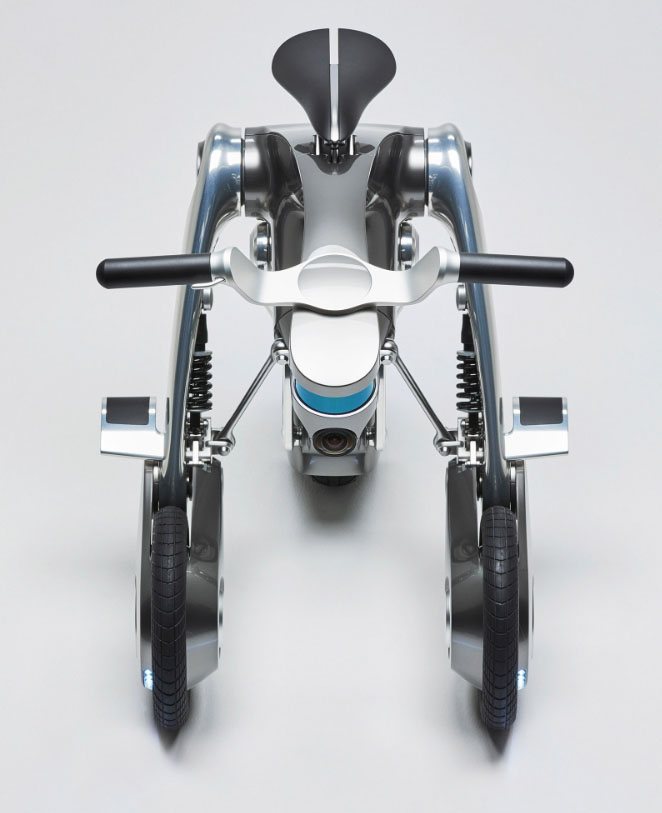
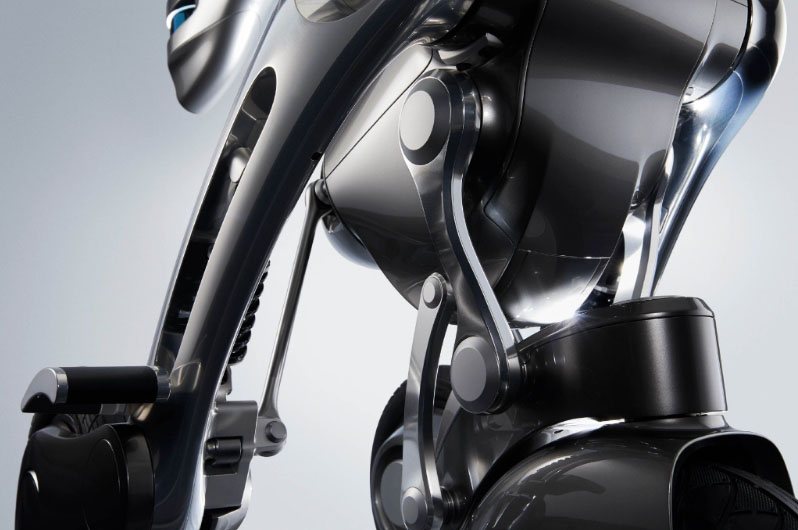 إذا نظرت بعناية إلى الجزء الأمامي من الروبوت، فستجد شيئًا يشبه القناع أسفل المقودين على شكل الأذن، والذي يضم نظام ليدار ثلاثي الأبعاد للمركبة، وكاميرا واسعة الزاوية أسفله.
يوجد أيضًا مستشعر مسافة داخل الصندوق الأسود الصغير، وتعمل أجهزة الاستشعار هذه بشكل أساسي كعيون CanguRo.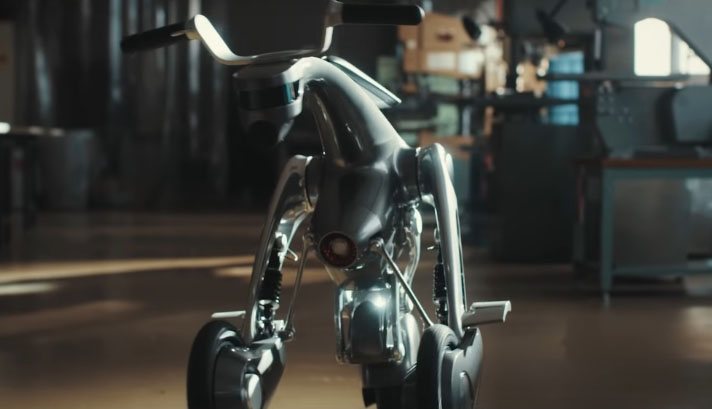
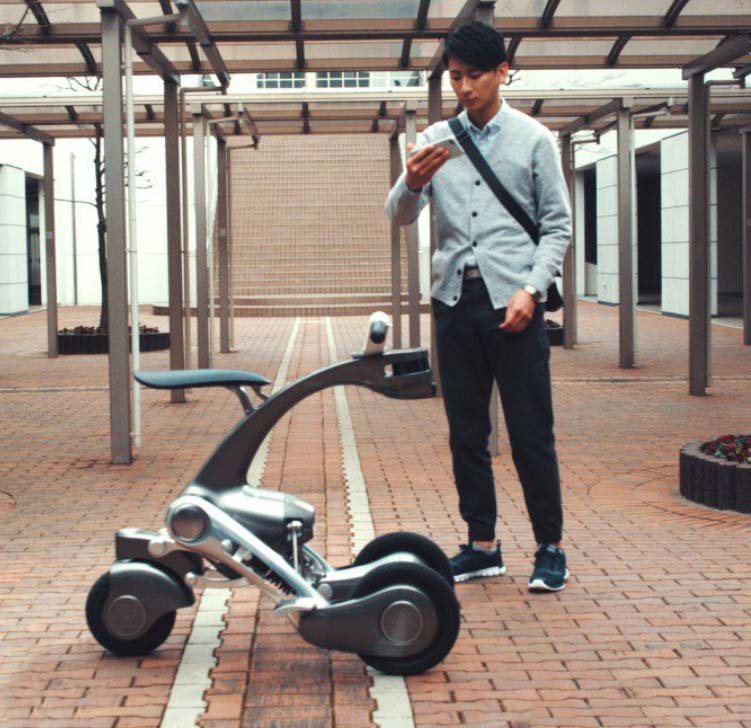 من أجل ضمان أنك لن تضيع، فهي تحتوي أيضًا على نظام ملاحة متقدم مدمج تم تطويره بشكل مستقل بواسطة FuRo.
In this navigation system, there is an important software called SLAM, which can synchronize the positioning of the vehicle and use the signal data received by the sensor. The surrounding environment is mapped in real time, and the vehicle's self-driving system then creates a path plan based on the surrounding environment and obstacles for autonomous navigation.
وبفضل هذه التكنولوجيا على وجه التحديد، يمكن للسيارة القيادة إلى وجهتها بشكل مستقل وآمن. أو يمكن للمستخدمين أيضًا التحكم لاسلكيًا في CanguRo من خلال جهاز لوحي أو هاتف ذكي، مما يسمح له بمتابعتهم بشكل فعال.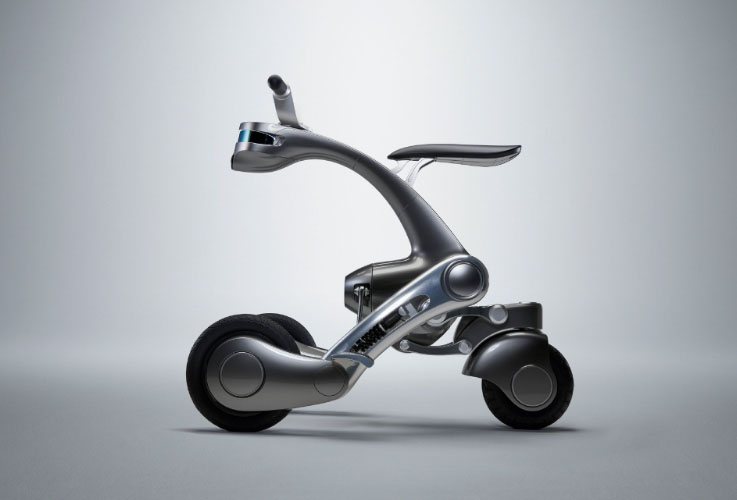
 عندما تريد ركوب هذه الدراجة، ستتحول من وضع Roid إلى وضع Ride.
في هذا الوقت، سيقوم CanguRo بتنفيذ سلسلة من إجراءات التشوه. تبدو وكأنها أداة ركوب مشابهة للدراجة ثلاثية العجلات الكهربائية المقلوبة أو السكوتر.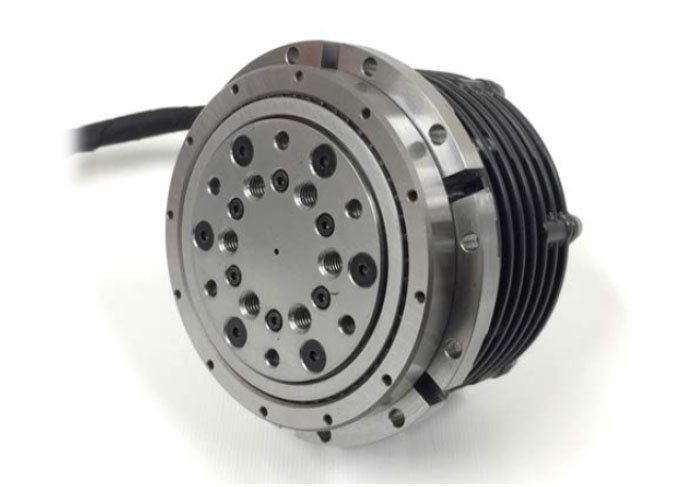 وتأتي القوة الدافعة للمركبة من المحركات عديمة الفرشاة المدمجة في العجلتين الأماميتين مقاس 12 بوصة، ويتم التوجيه من خلال العجلات الخلفية السميكة مقاس 10 بوصة.
 على الرغم من أن المحرك لا يوفر معلومات محددة عن الطاقة، إلا أن بعض البيانات تشير إلى أن السرعة القصوى للمحرك هي 4200 دورة في الدقيقة، وأن الحد الأقصى لعزم الدوران هو 0.93 نيوتن متر فقط.
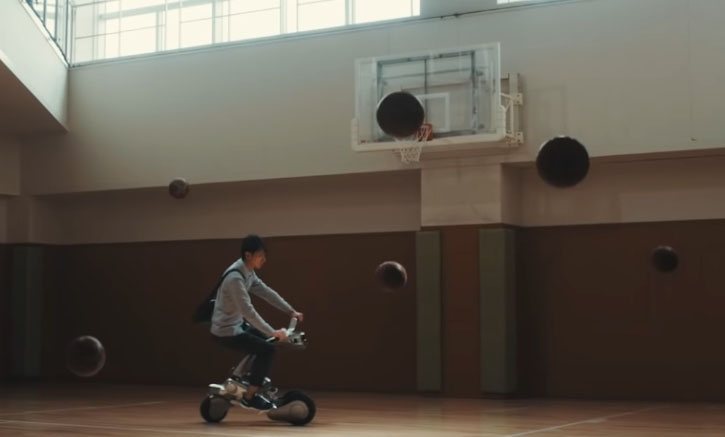
من الواضح أن مثل هذا المحرك CanguRo لا يمكنه مساعدة مالكه على الفوز بأي مسابقات متعلقة بالسرعة. بعد كل شيء، السرعة القصوى الرسمية المحددة هي 10 كم / ساعة فقط، ولكن يجب أن تسمح للراكب بالتجول في الشوارع والأزقة بطريقة أكثر استرخاءً.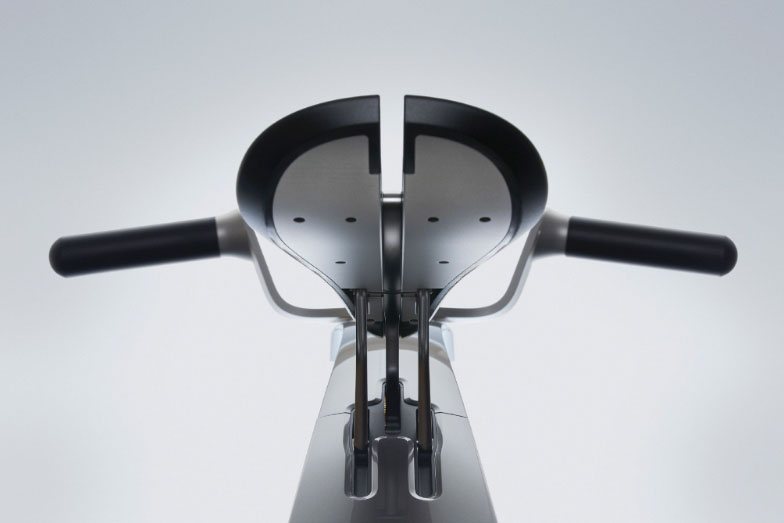 عندما يتعلق الأمر بتجربة الركوب وأسلوب القيادة، فإن CanguRo تختلف تمامًا عن الدراجات ثلاثية العجلات الكهربائية المعروفة حاليًا.
لأنه بدلاً من استخدام شاشة بديهية للسماح للراكب بمعرفة السرعة الحالية، يستخدم السكوتر الكهربائي الآلي بوزن 64 كجم حاسة لمس رائعة.
It has a built-in haptic device under the seat cushion, which will send out an increasing beat to let the rider feel that the vehicle is accelerating, and the pedals are located on the swing fork next to the in-wheel motor, so that the rider's legs can also feel the acceleration of the vehicle. The driving force behind CanguRo. 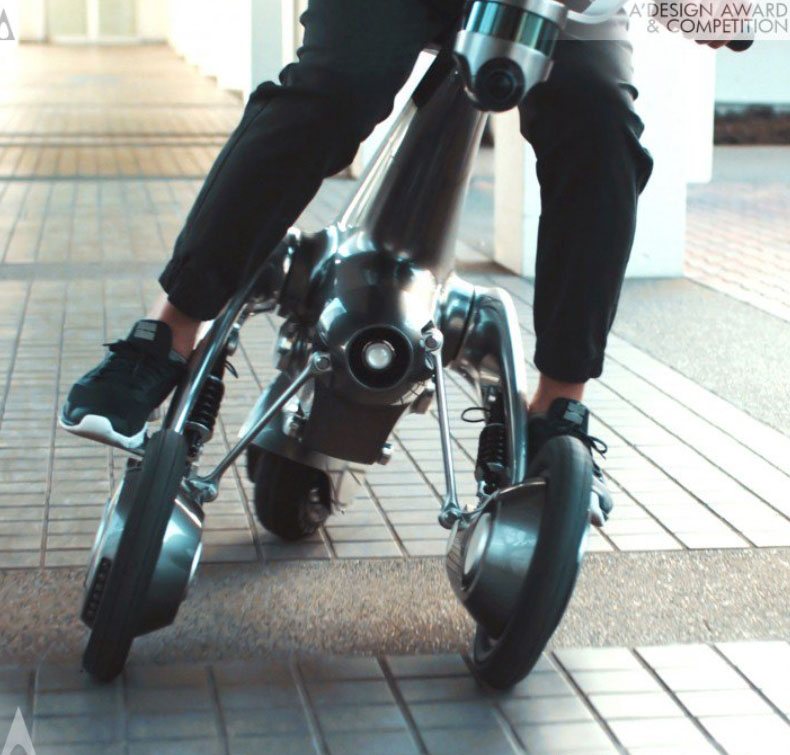 عندما يحتاج الراكب إلى الدوران، سيكتشف مستشعر القوة في نظام تعليق السيارة اتجاه ميل الراكب ويرسل ردود فعل القوة إلى المقود لتوجيه السيارة إلى الدوران.
إذا اكتشف CanguRo عائقًا أمامه ولكن الراكب لم يقدم تعليقات، فسيظل يختار تجنب الاصطدامات بشكل فعال. عندما يتنبأ باحتمال وقوع حادث، يقوم تلقائيًا بالضغط على الفرامل. منطق السلوك مشابه لمنطق الحصان الحقيقي. الخيول هي نفسها تقريبا.
في رأيي الشخصي، سواء كانت حركات التشوه المثيرة للاهتمام لـ CanguRo، أو أسلوب الركوب الخاص أو حتى الأداء الذكي، فإنها تتناسب حقًا مع مظهرها المستقبلي بشكل جيد للغاية.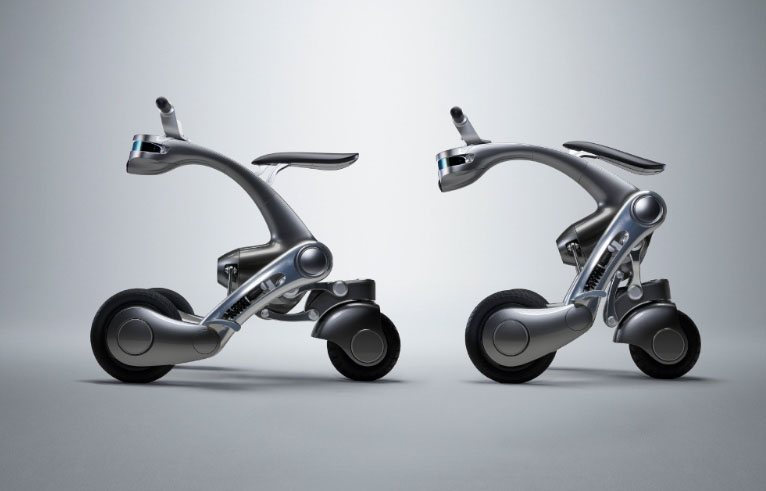 للأسف، في حين أن هذه السيارة الكهربائية الروبوتية الممتعة تبدو جاهزة تمامًا للإنتاج، فمن غير المرجح أن نراها معروضة للبيع في أي مكان، حيث تعتبر Furo أن CanguRo هو مشروع بحثي، وبقدر ما ستستخدمه، فإن نوع نظام البطارية وأداء عمر البطارية غير معروف أيضًا.
If this rideable robot ever hits the market, it will certainly have an impact on human psychology, such as raising a group of lazy humans, who let our brains be designed in this way-to perform bodily functions. Store as much energy as possible. But one thing is undeniable, that CanguRo is indeed one of the coolest robots we have seen in the past two years.
روبوت التسليم؛ روبوت AMR؛ روبوت الإرسال


